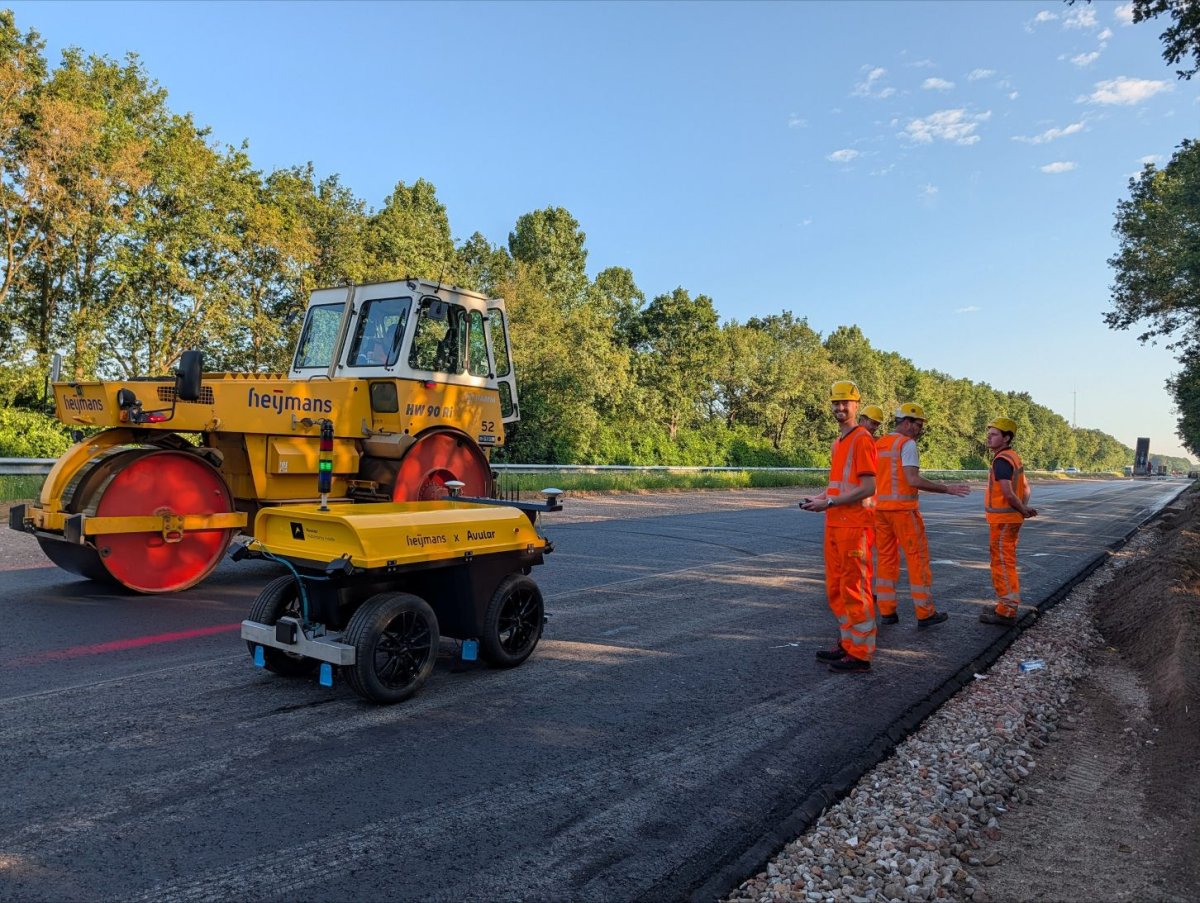
Development, Implementation, and Experimental Validation of a Model Predictive Controller for an Autonomous Road Roller
When
Thursday 08 October 2026
· 13:30–16:00
Where
Neuron 0.116
Speaker
D
Dani Peeters
About this event
This thesis presents the development and experimental validation of a Model Predictive Controller (MPC) for autonomous road rollers. The controller aims to improve path-tracking accuracy while accounting for vehicle dynamics and actuator constraints. Its performance is evaluated through simulations and real-world experiments and compared with an existing Pure Pursuit controller. The results demonstrate the potential of MPC for accurate and reliable autonomous road compaction.
Host