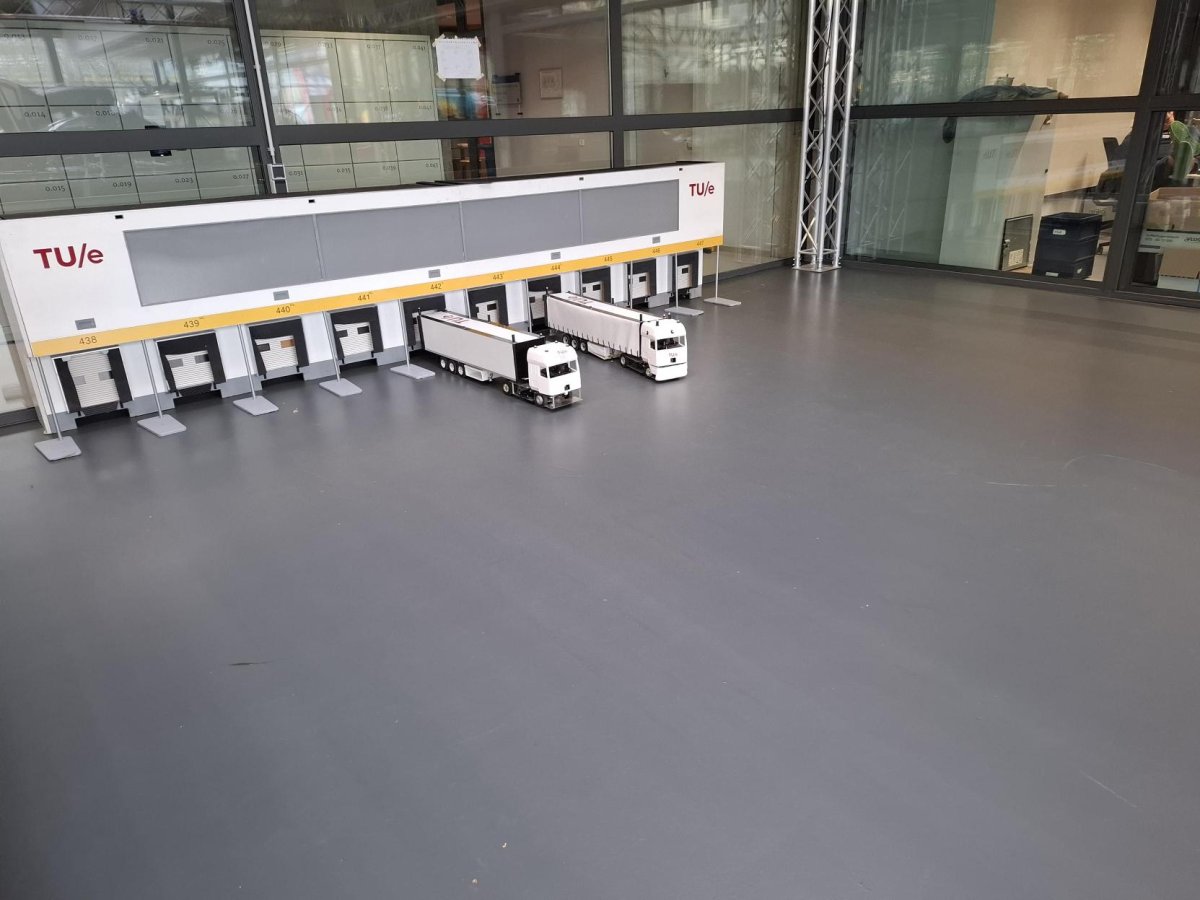
Simulation and Experiment Environment of Truck–Trailer System in Truck Lab
Speaker
Shao-An Huang
About this event
This thesis presents a systematic methodology for the development, validation, and implementation of simulation and experimental environments for a truck and a truck–trailer system based on kinematic vehicle models. The models are validated against experimental measurements obtained from the TU/e TruckLab platform, with identified steering actuator dynamics incorporated to improve the representation of the physical system. Based on these validated models, a simulation environment is developed for controller design and evaluation using predefined straight-line and circular reference trajectories and corresponding tracking-error definition. Following simulation-based verification, the controller can be transferred to the TruckLab experimental platform for experimental evaluation. The performance of different controller designs is evaluated and compared, and their limitations and potential sources of discrepancies between simulation and experiments are discussed. A user guide is also provided to facilitate the use of the developed simulation environment.
Host